One adaptable tool for every kit and every operator
FutureMakers produces 17 different hands-on STEM kits for PK-8 classrooms. Its kitting workforce includes operators with a range of physical and intellectual disabilities, so the solution needed to reduce fatigue and cognitive load without removing human control from the process.
Our research covered more than 2,000 observed kit assemblies across multiple operators and multiple kit configurations. It showed that bag handling was among the most inefficient and inconsistent steps: operators had to separate a resealable bag, keep it open, and retrieve parts from multiple bins at the same time.
The challenge was not simply to automate the line. The system needed to target a 30% reduction in kitting time and eliminate undercounts while preserving meaningful human interaction and operator control. That requirement ruled out many conventional automation approaches and made accessibility, simplicity, and adaptability central engineering constraints.
The bag opener and holder
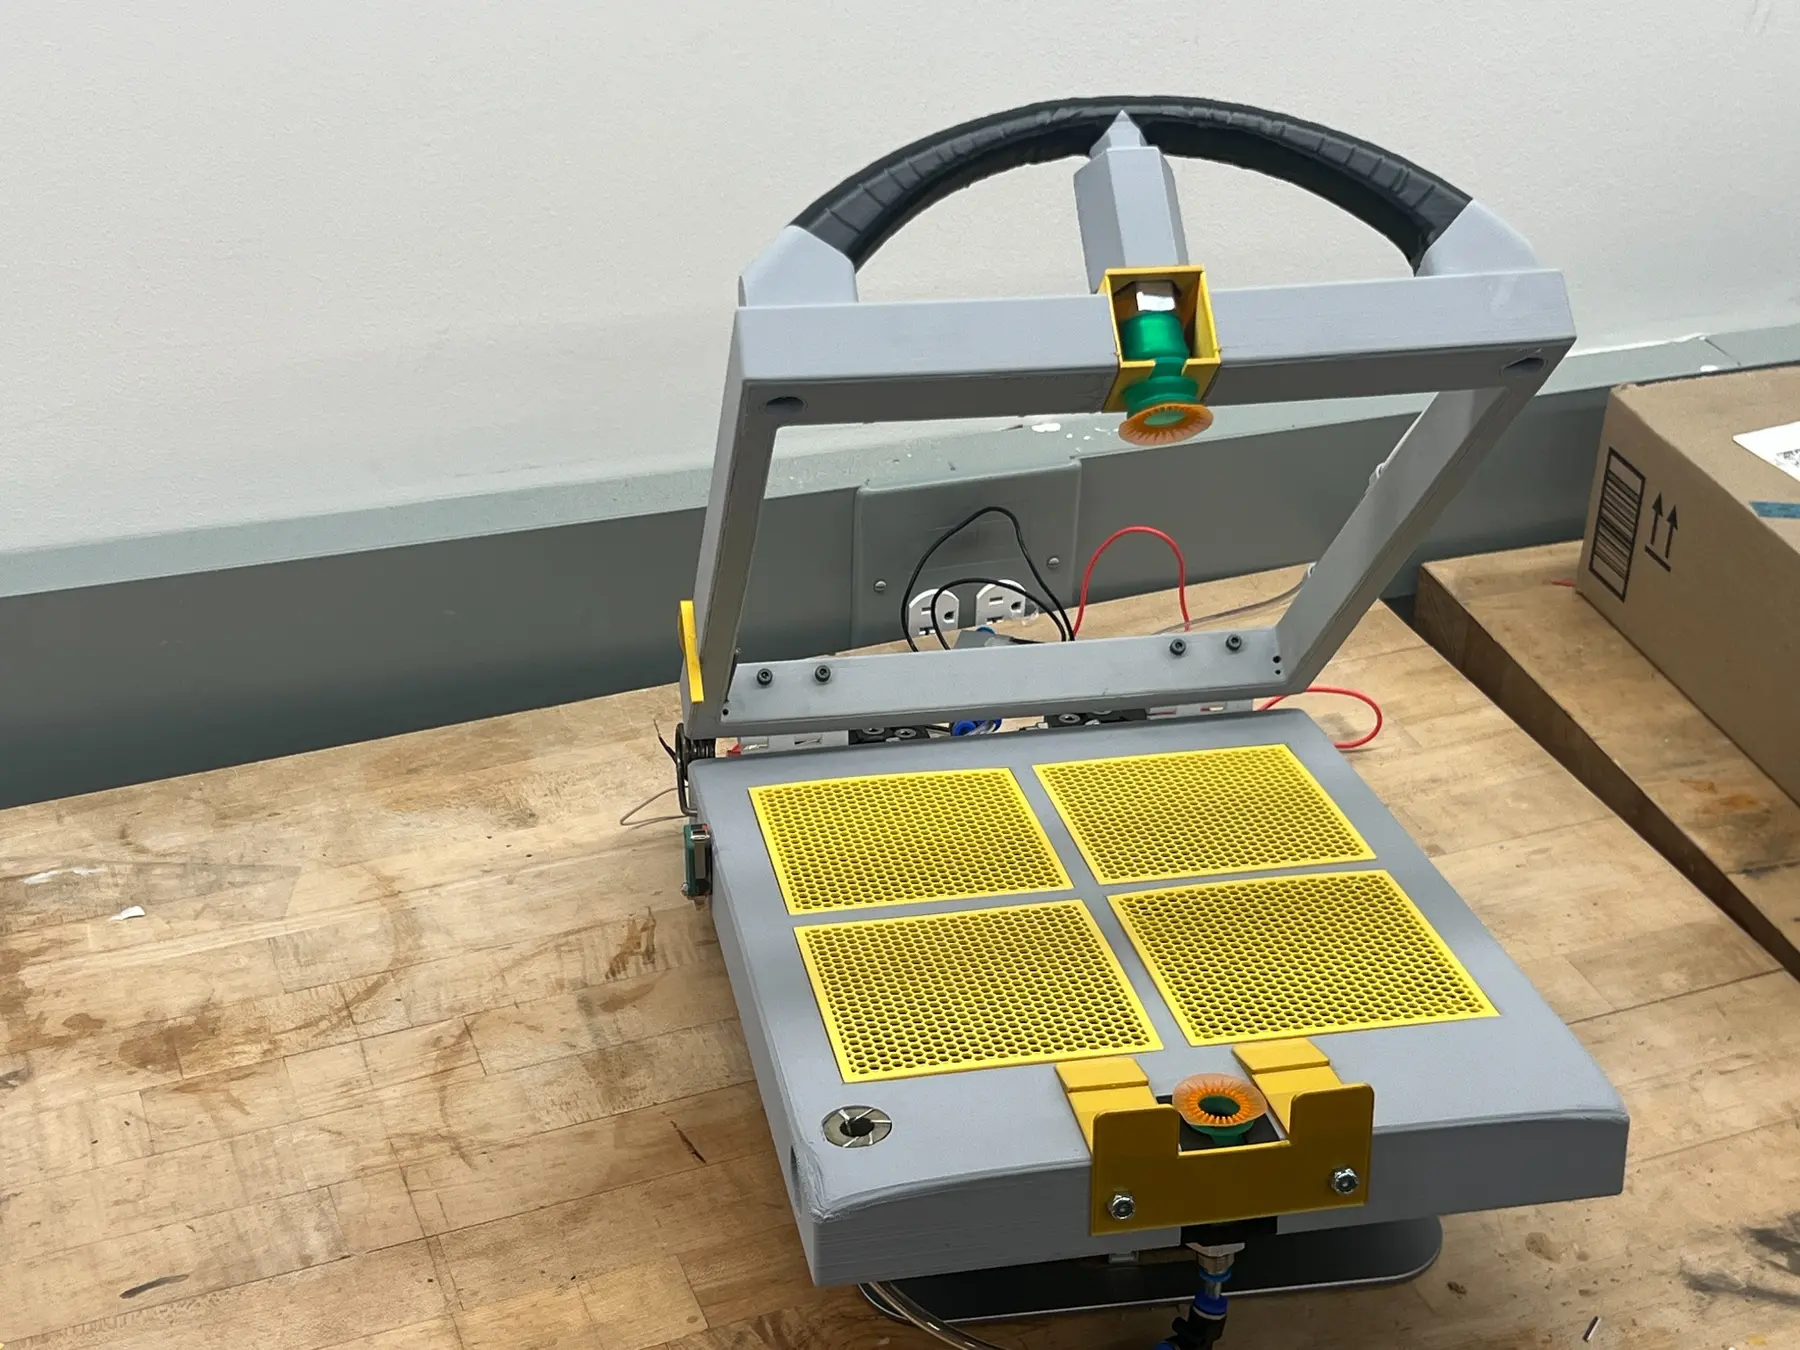
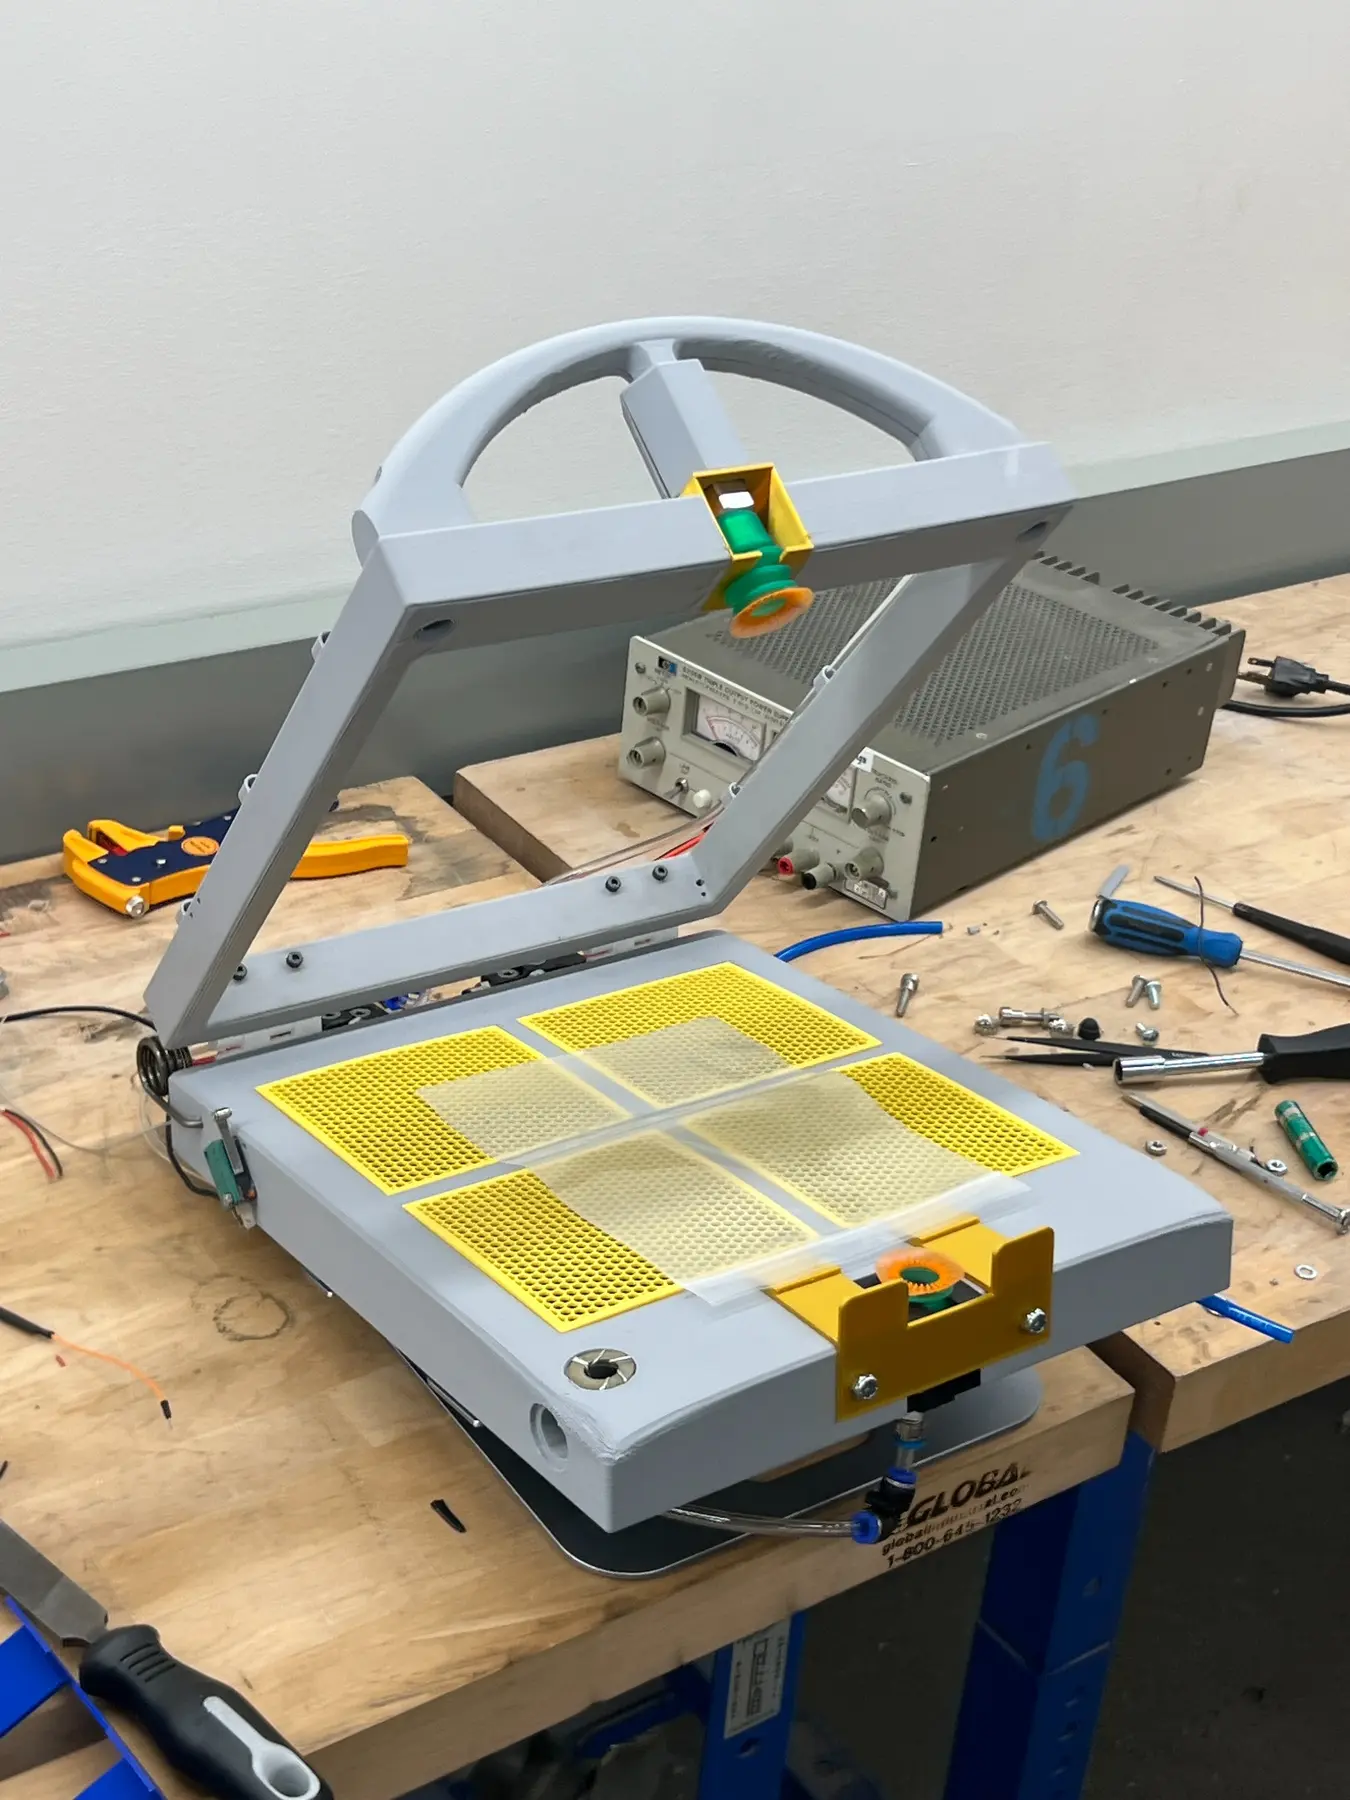
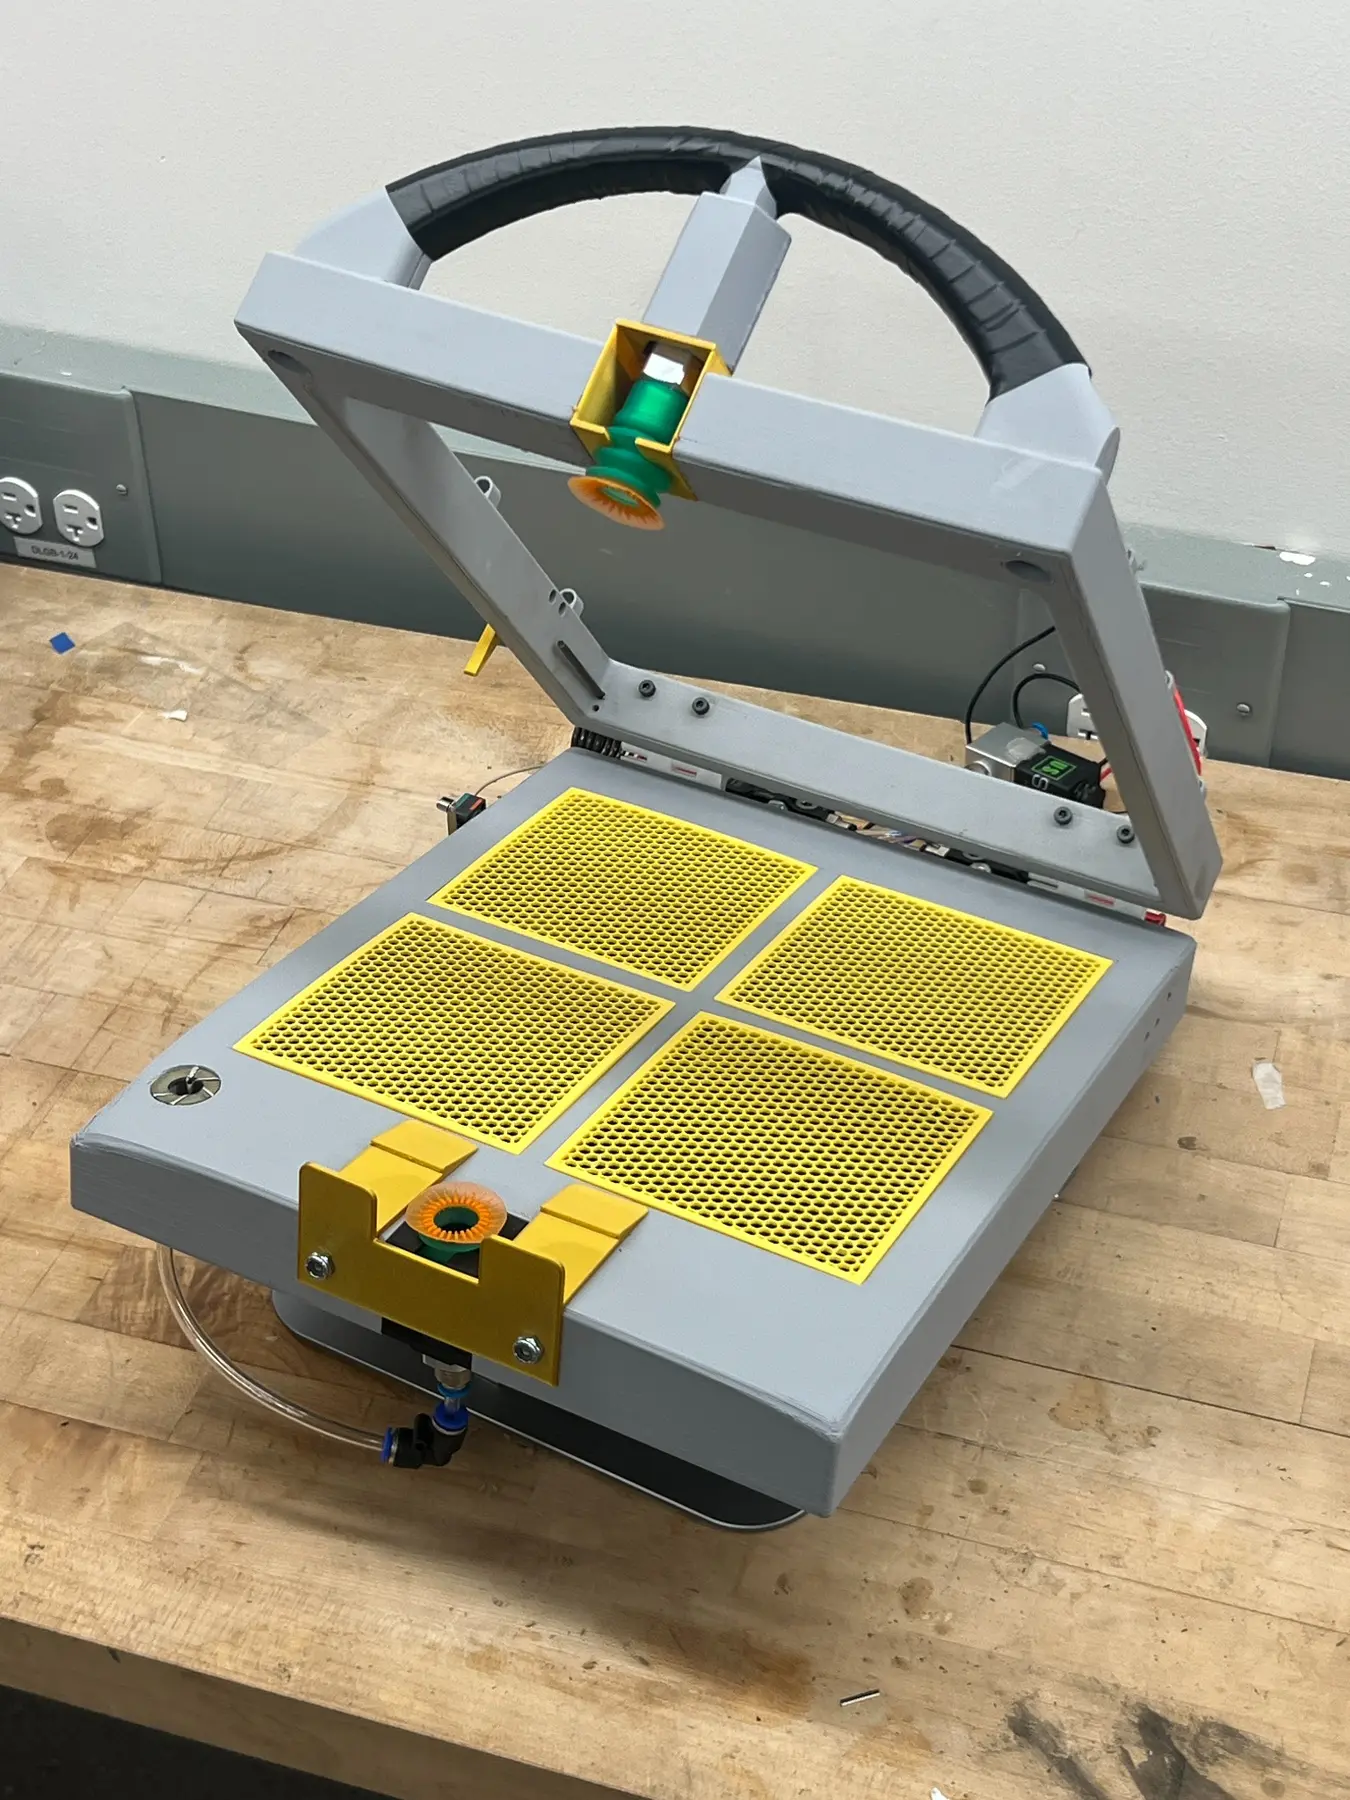
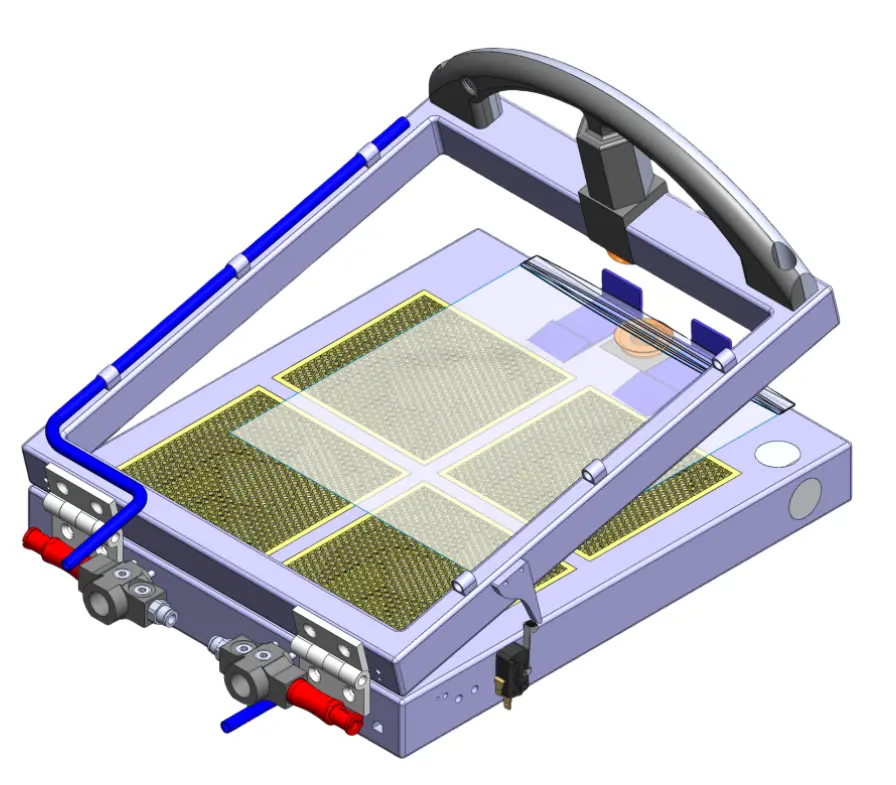
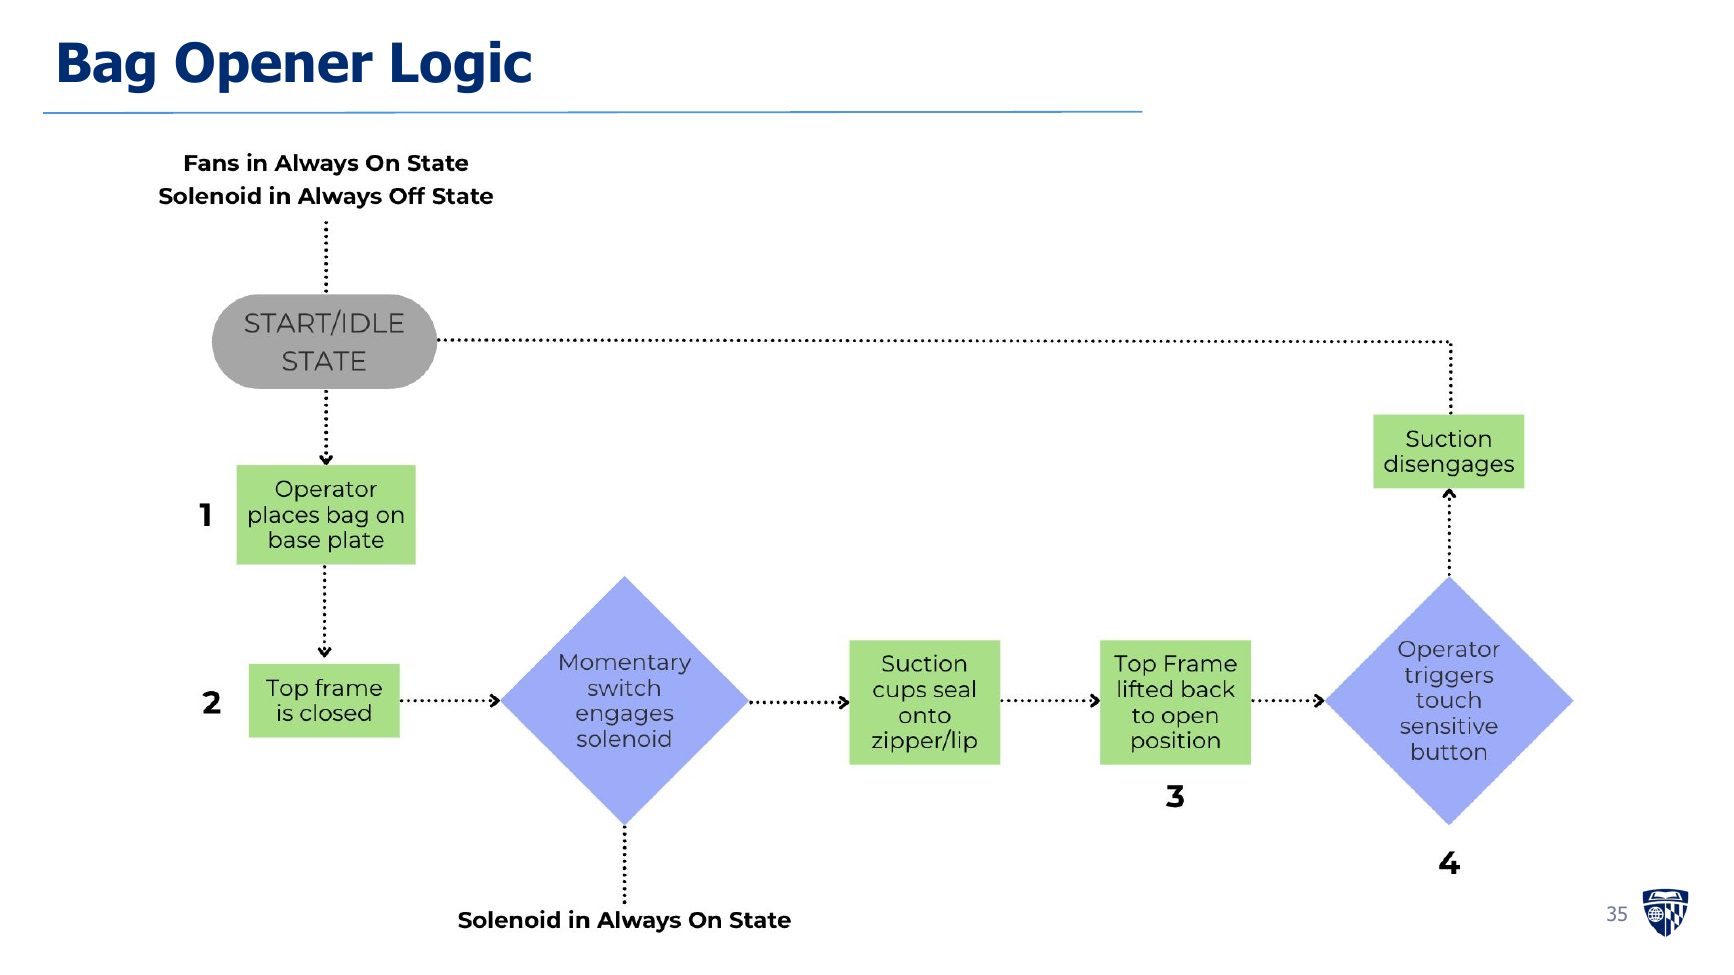
The device combines a hinged, spring-assisted frame with opposing suction cups. The operator positions the bag against a front stop, presses the handle to establish the seals, and lifts the frame to separate the lips. Vacuum remains active until the operator touches the capacitive release disc.
Proving the mechanism
This functional prototype was the final working iteration before the polished model was built. It validated the complete bag-placement, suction, opening, hands-free holding, loading, and release sequence while the mechanism and controls were still exposed for rapid troubleshooting.
Polished integrated model
After proving the operating sequence, the team carried the mechanism into the finished gray-and-yellow assembly shown below, integrating the frame, controls, pneumatic routing, protective panels, and operator-facing features into a presentation-ready design.
Designed around reliable suction and simple control
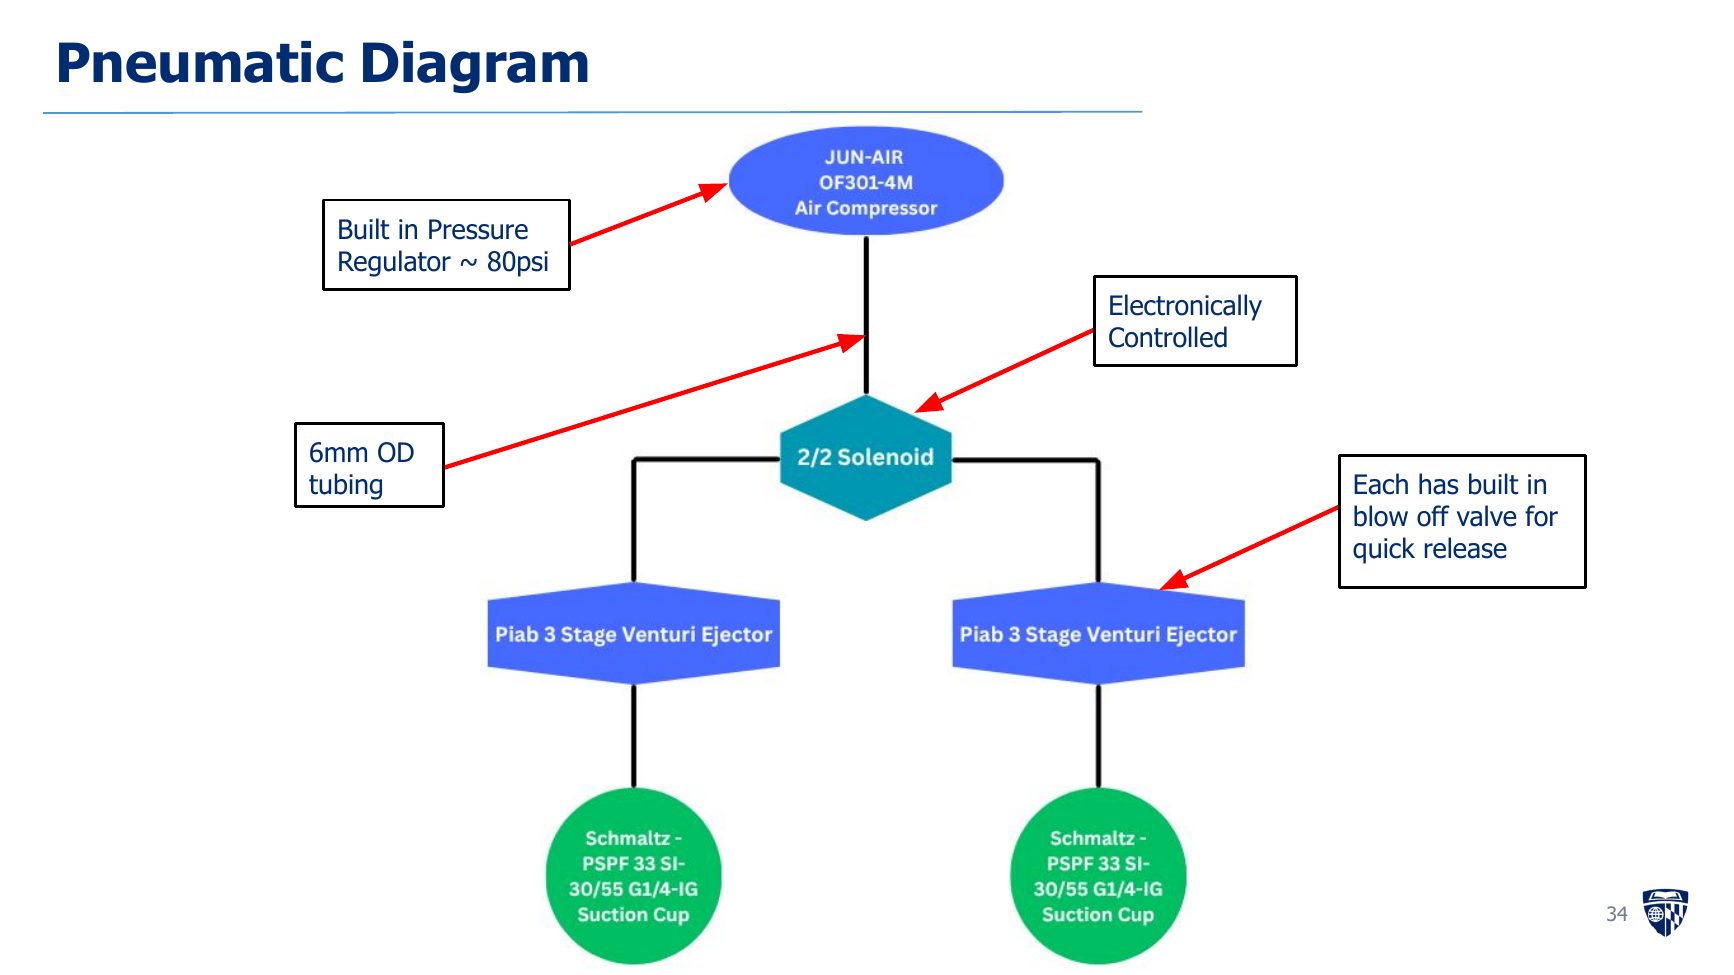
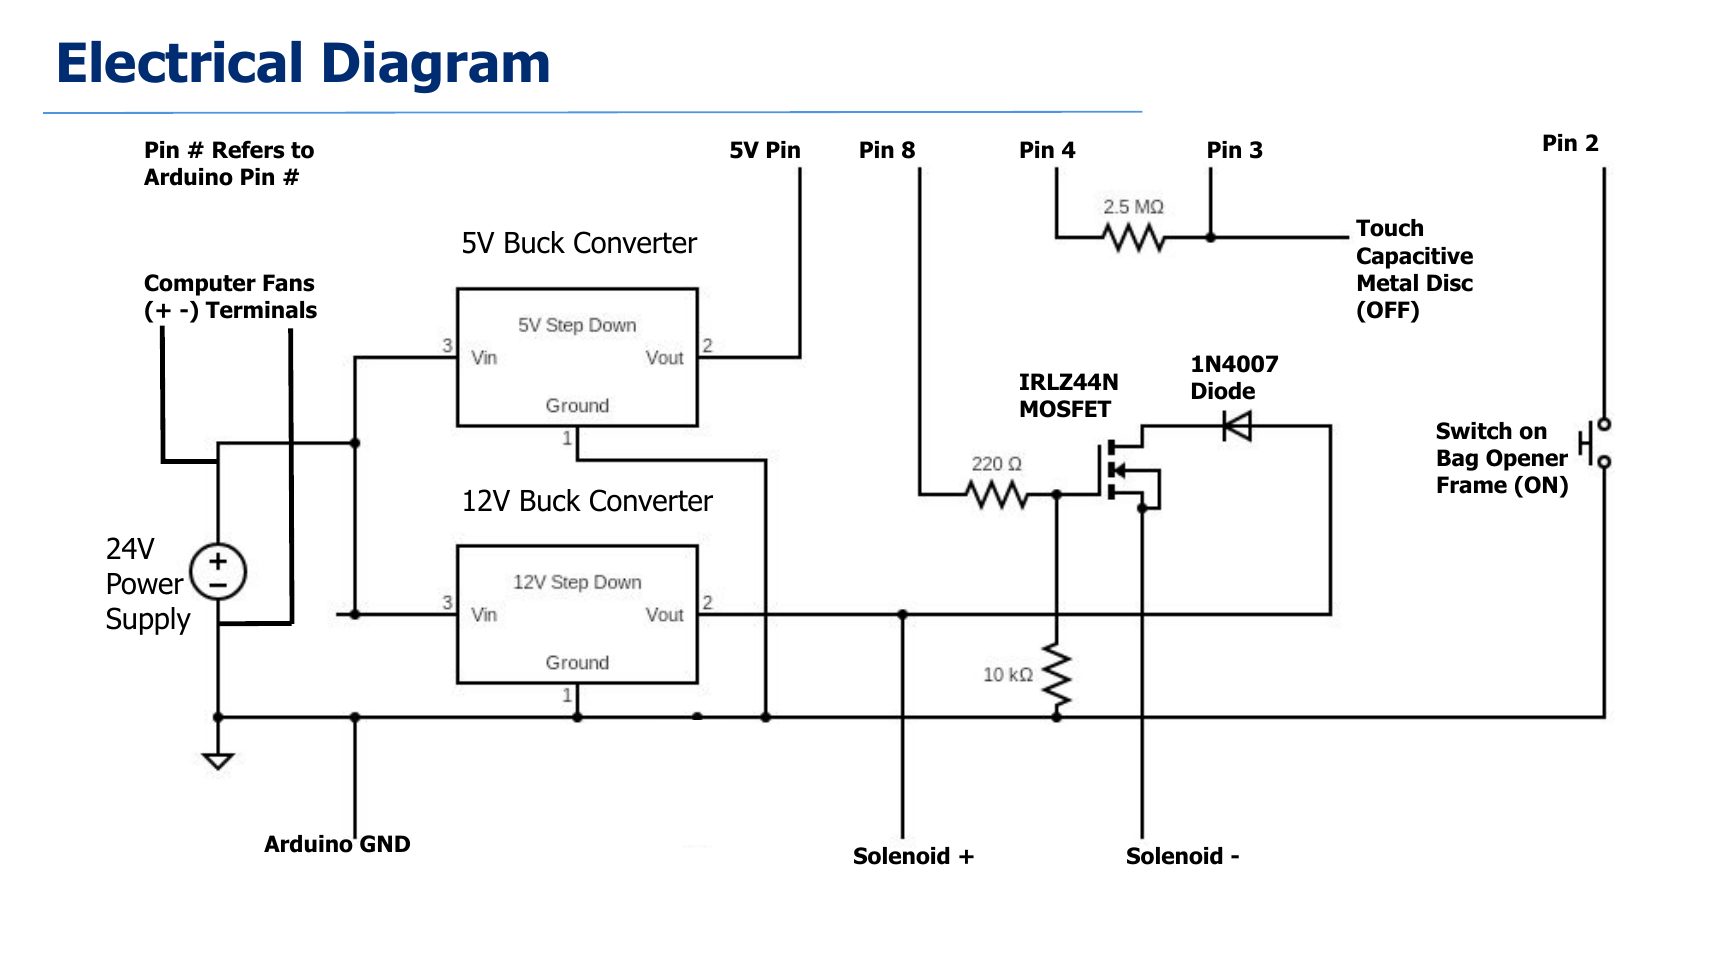
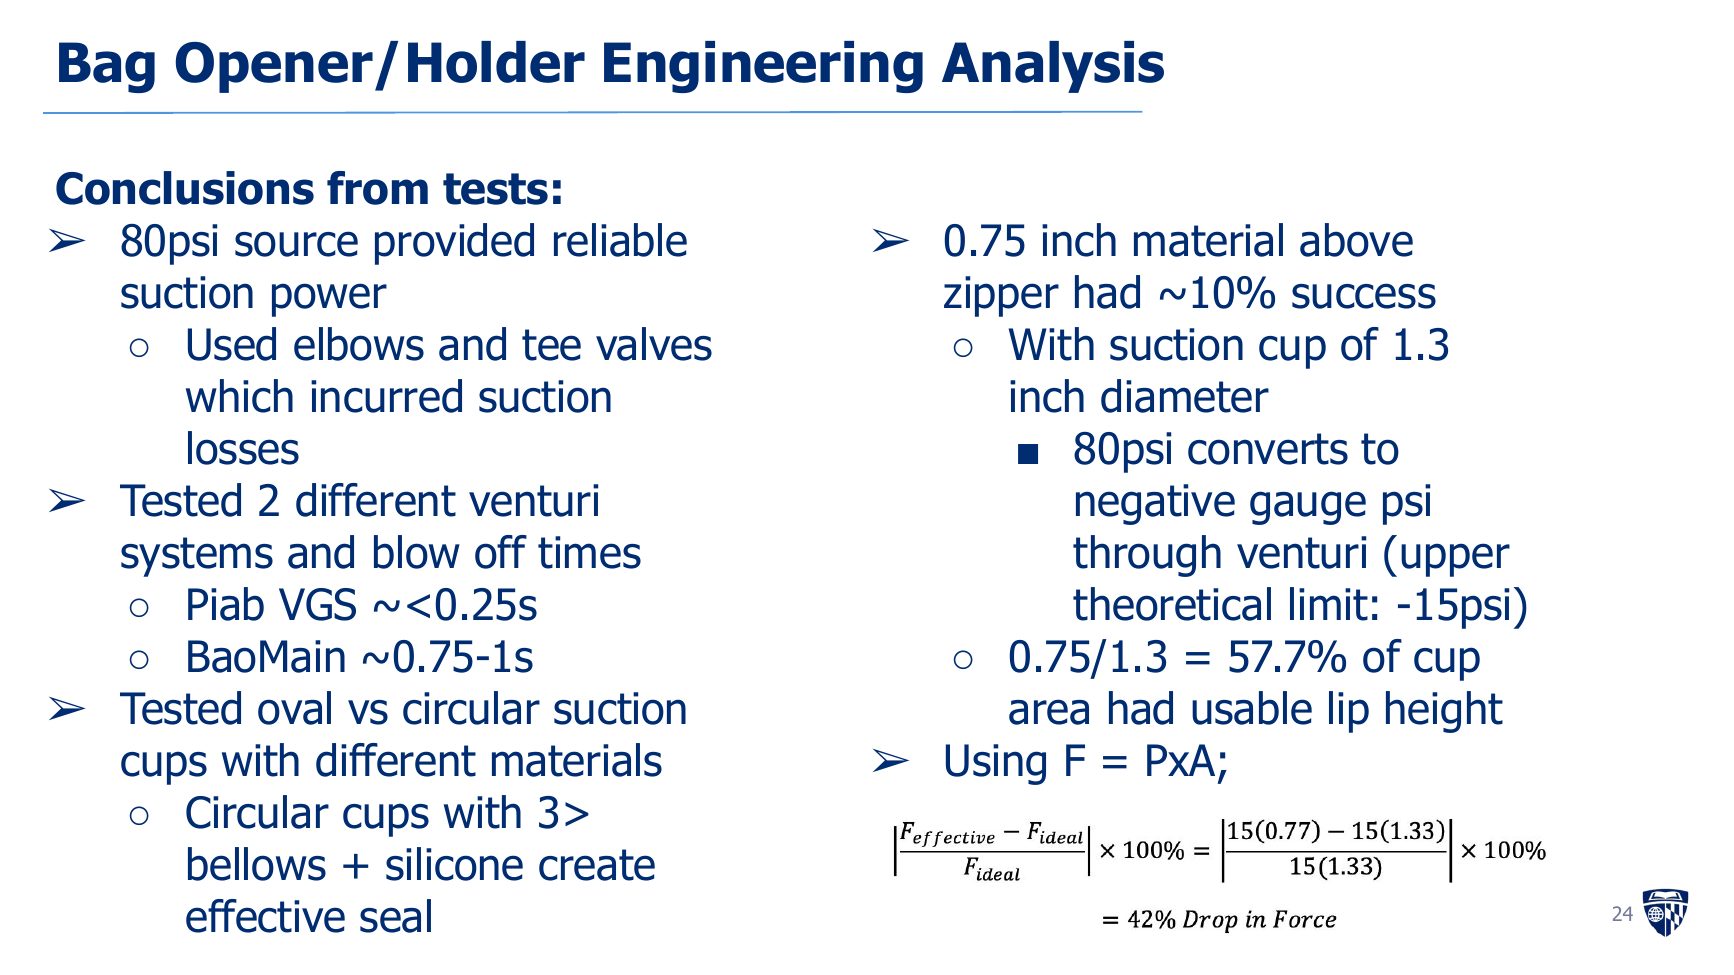
The pneumatic architecture was refined through component testing rather than assumption. More than ten suction-cup variants were evaluated before selecting multi-bellows silicone cups that conformed reliably around the bag zipper. The final system used 6 mm tubing, check valves at the cups, regulated shop air, electronically controlled valves, and a fast-response Piab venturi.
My role and ownership
On the bag-opening subsystem, I contributed to mechanical design, SolidWorks CAD, component selection, pneumatic architecture, machining, 3D printing, soldering, Arduino control logic, integration, and iterative suction testing. My work connected the physical mechanism to a repeatable operator sequence that could be evaluated under realistic use.
Measured performance, not just a working demo
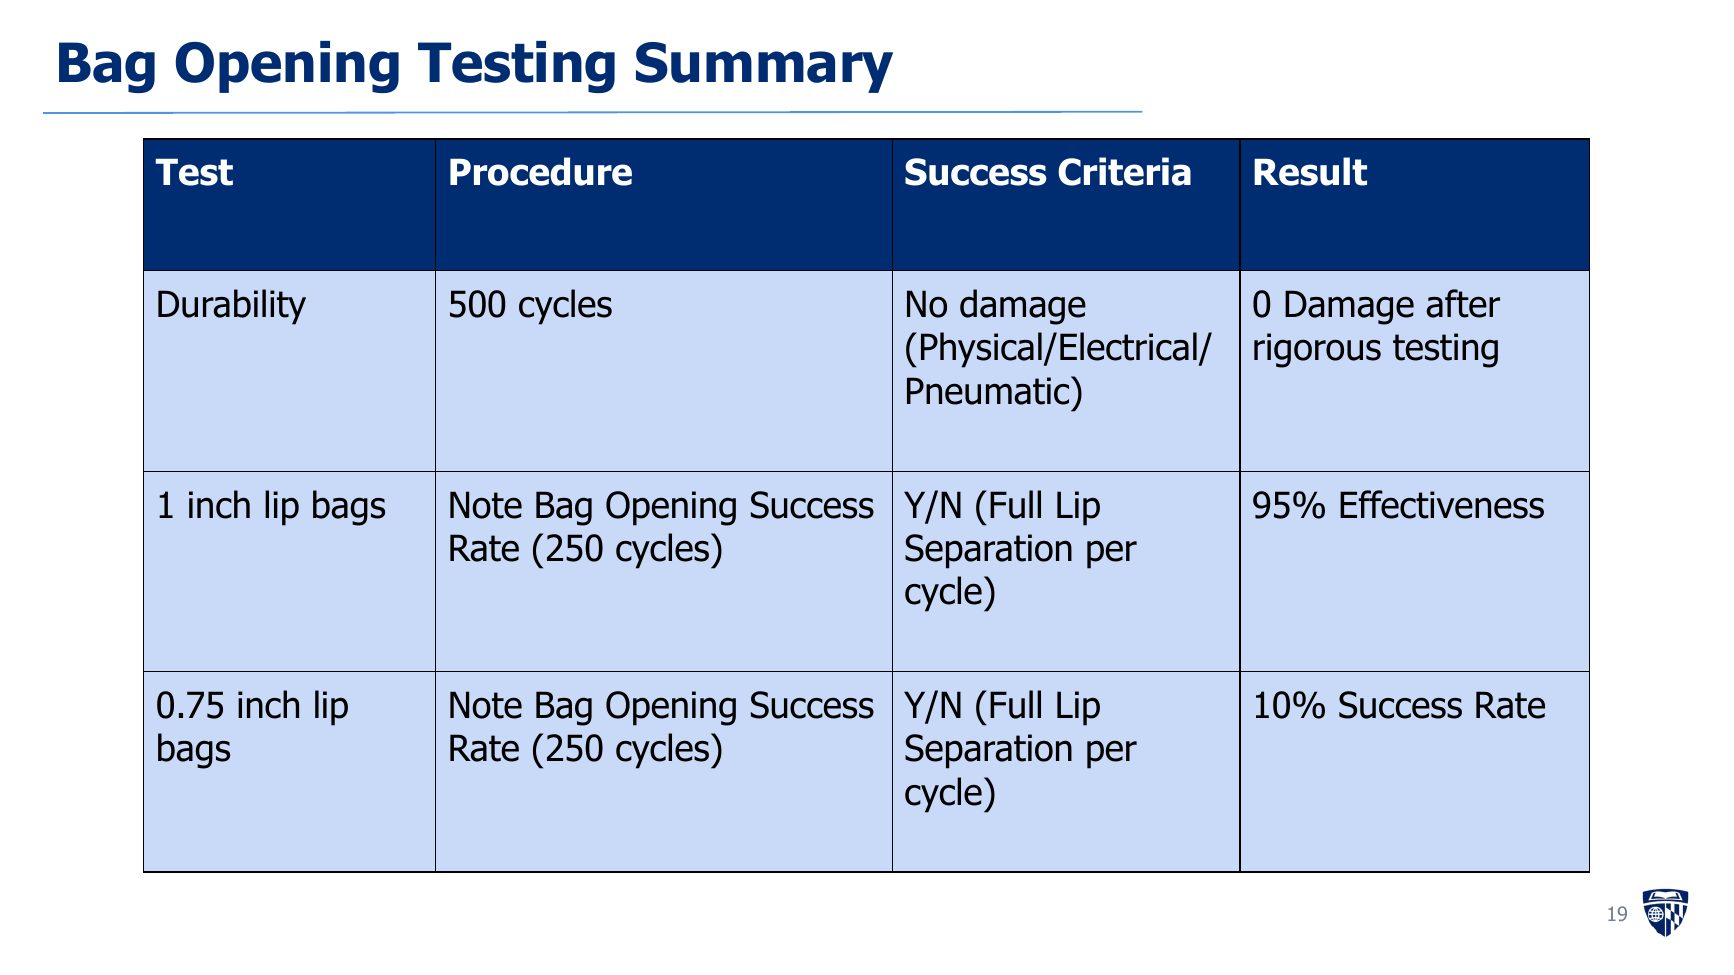
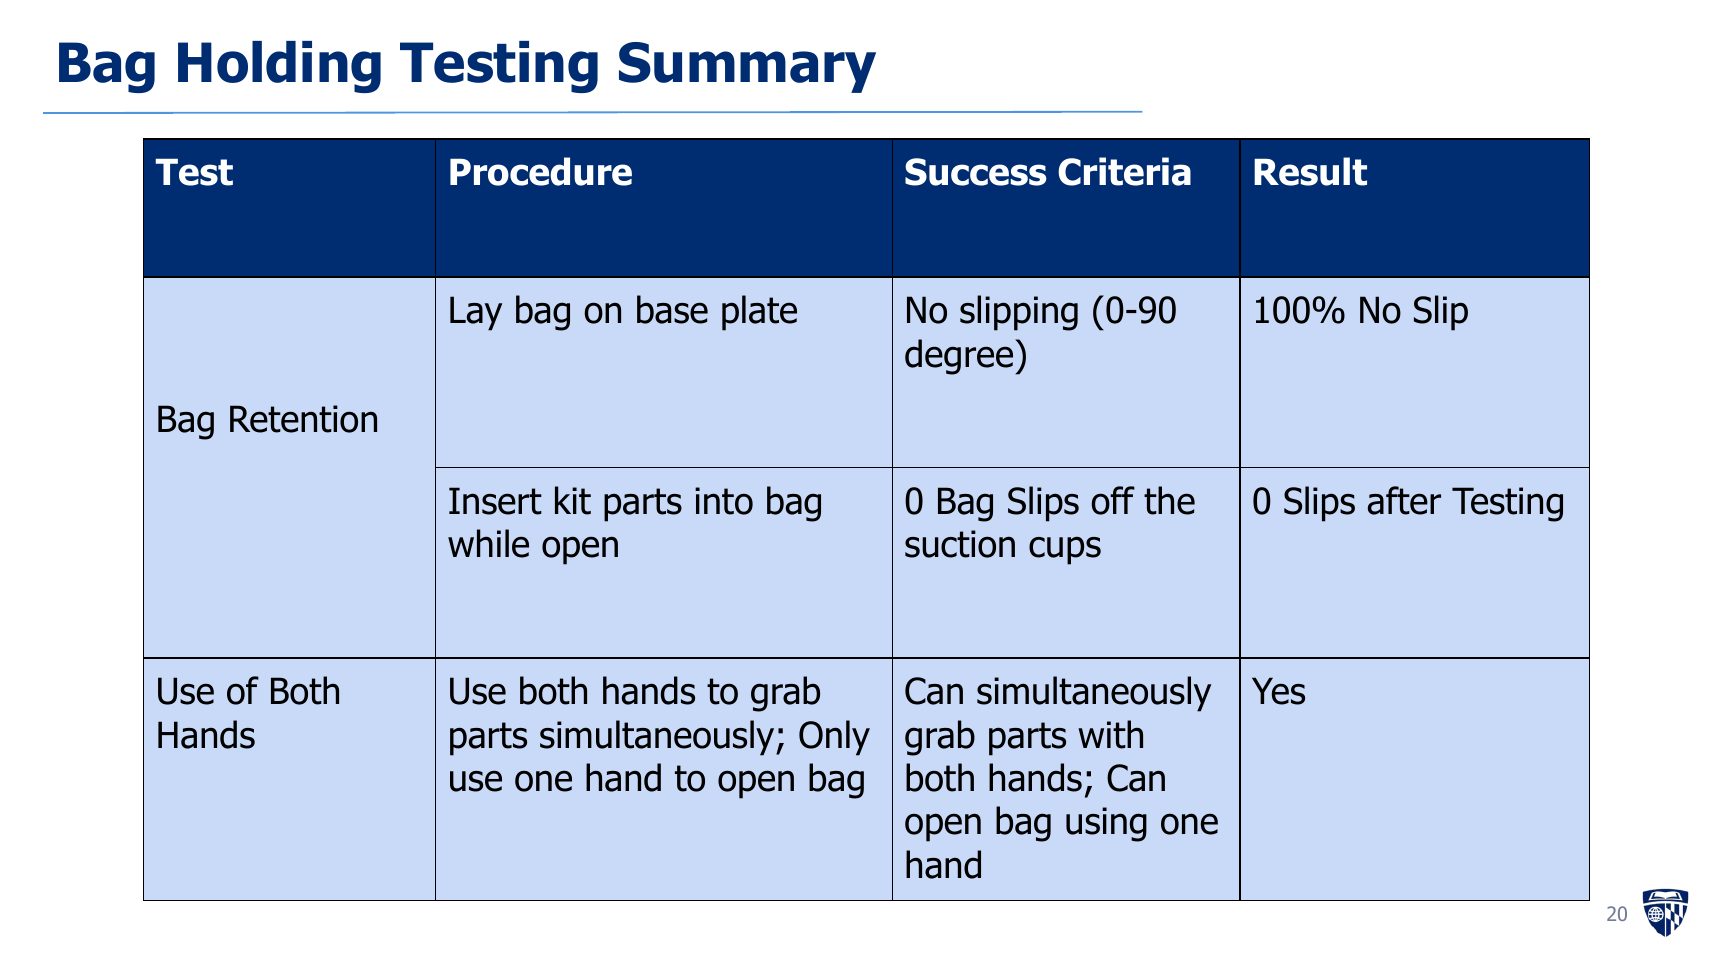
The device held bags from horizontal through vertical orientations and allowed operators to retrieve parts with both hands. Testing also identified a clear limitation: 0.75-inch bag lips produced only a 10% opening rate with the selected 1.3-inch cups, establishing smaller cups or standardized bag stock as the next design decision.
Computer-vision quality control
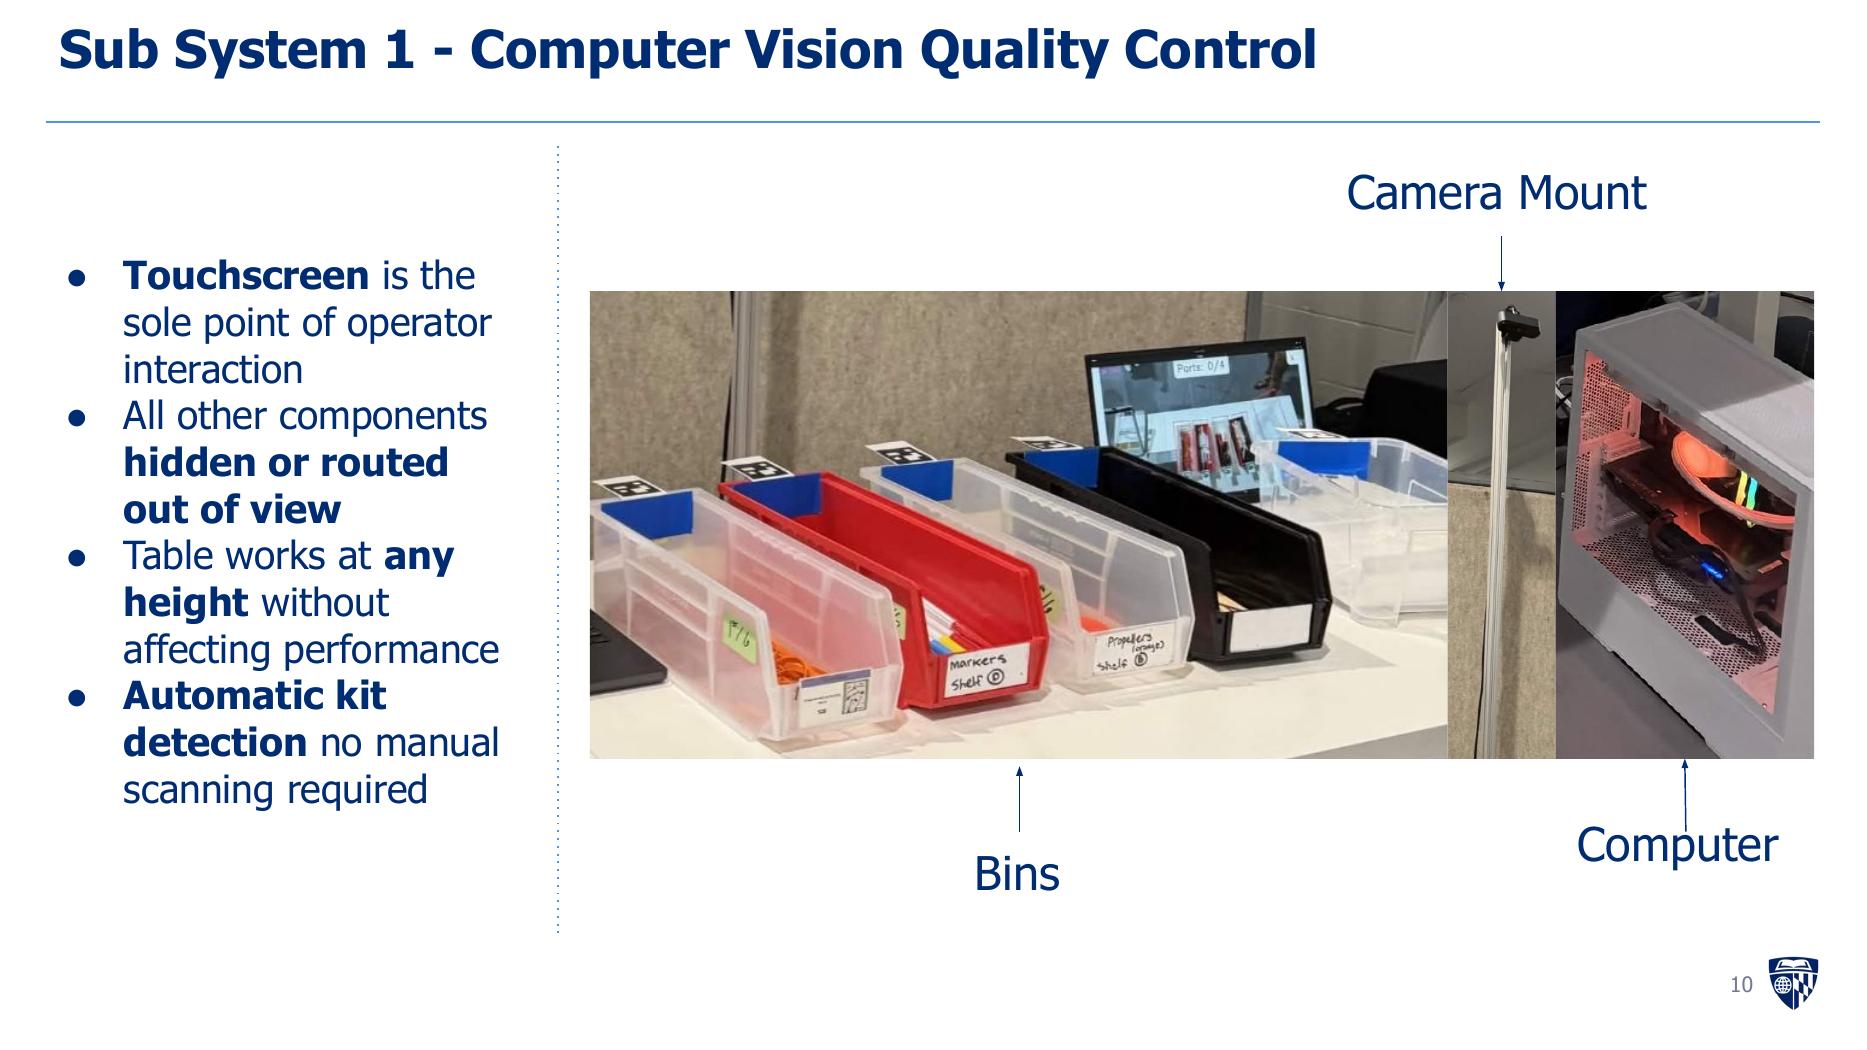
While the bag opener addressed physical effort, the computer-vision subsystem addressed the equally important requirement of eliminating undercounts without taking the operator out of the process. It watched the existing human workflow, confirmed each required bin interaction, and checked the kit when it reached the DONE bin.
How the system worked
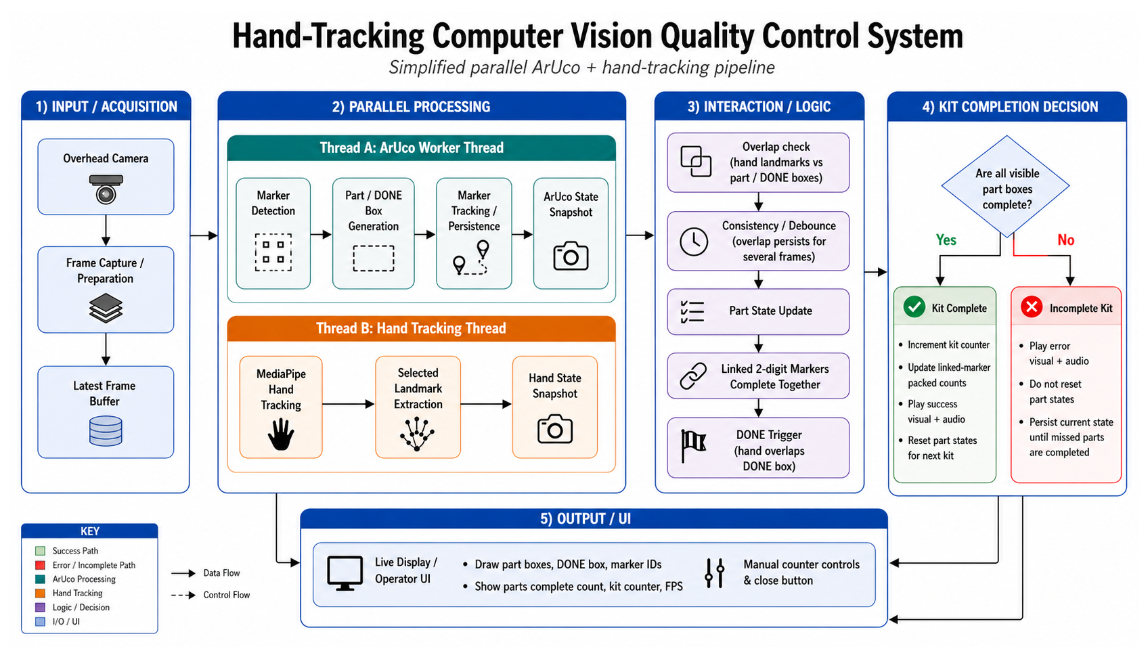
An overhead camera captured the full work area. ArUco markers identified the active kit, parts bins, and DONE bin, while MediaPipe tracked selected hand landmarks. The software compared the hand position with each bin region, required the overlap to persist across several frames, and updated the kit state only after a valid interaction.
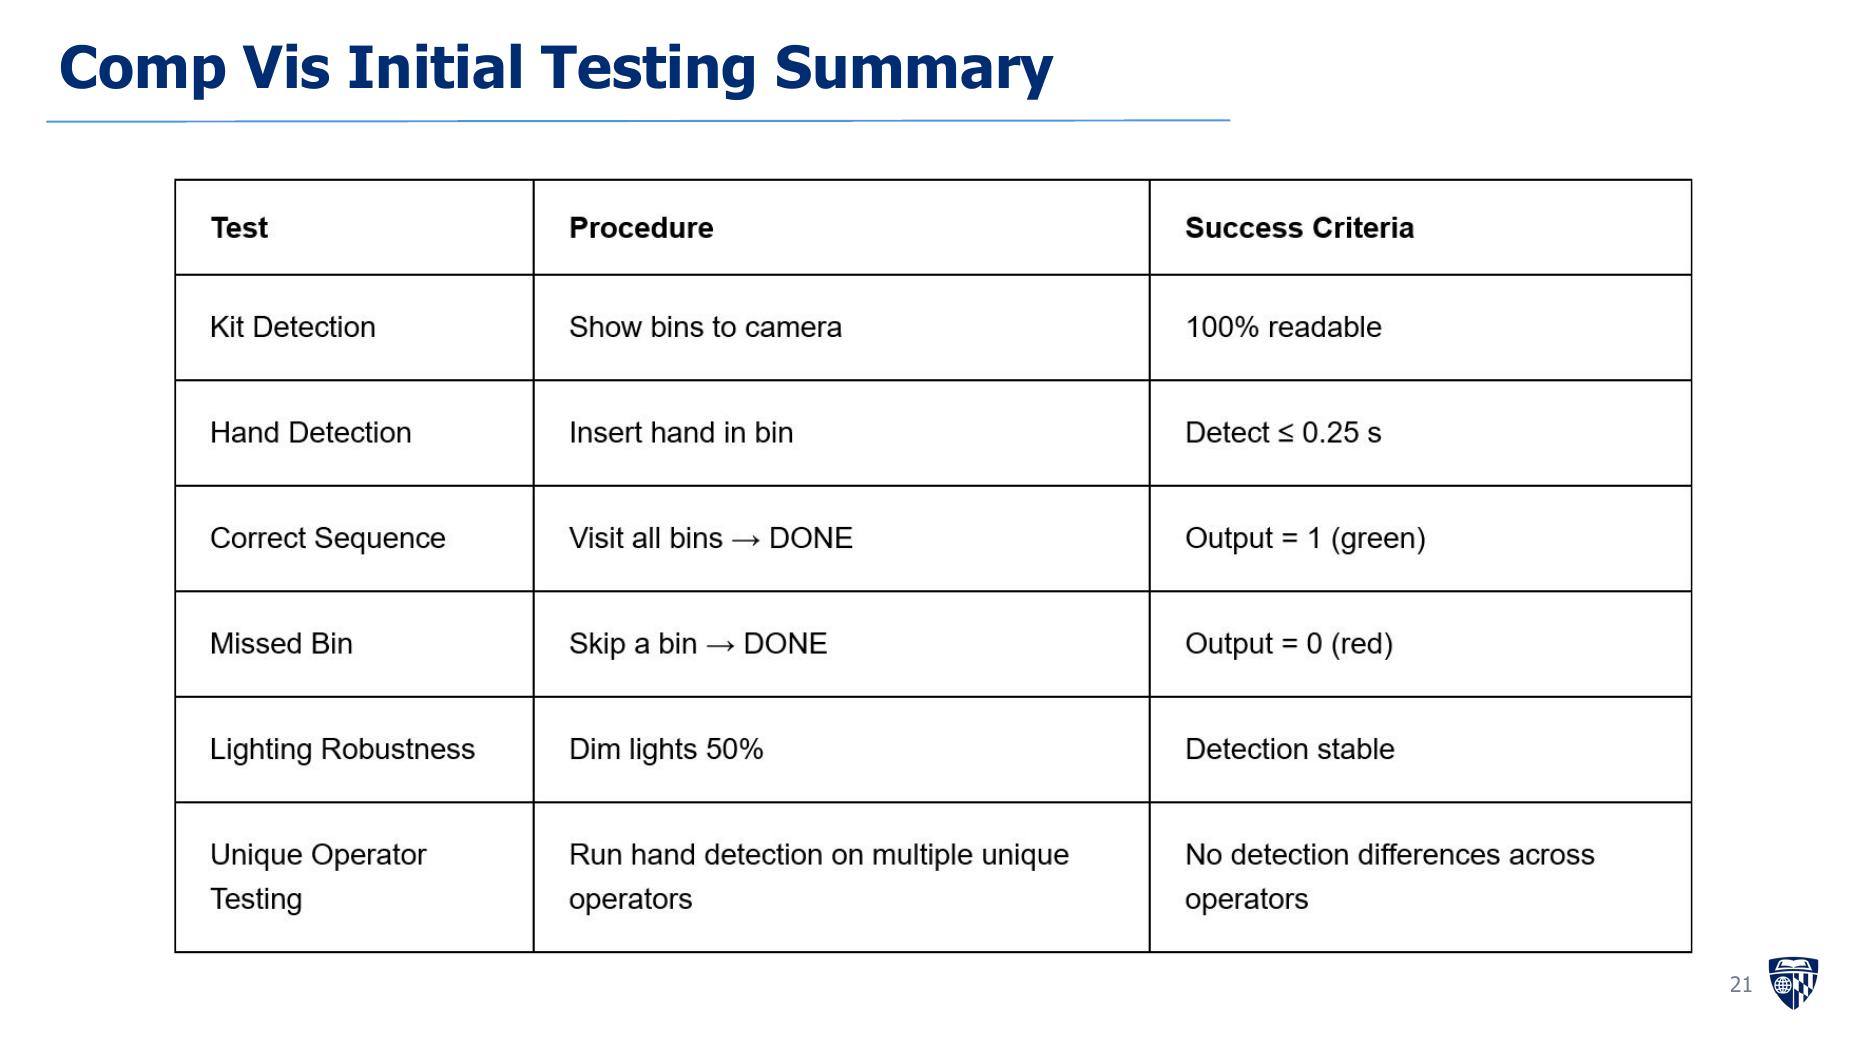
When the operator reached the DONE bin, the system evaluated the stored state. A complete kit produced green visual and audio feedback and reset for the next kit. If a required bin had been skipped, the interface displayed an error and retained the missing-part state instead of clearing it.
From camera placement to reliable tracking
- Determined the camera position and viewing geometry needed to keep the bins, hands, and DONE area visible.
- Troubleshot kit-detection, interaction, sequence, and completion logic.
- Helped optimize hand-tracking code and landmark behavior for more consistent hand-bin detection.
- Tested performance across different operators, kit layouts, lighting conditions, sleeves, and gloves.
- Helped translate observed failure modes into code and workstation adjustments.
Validation across operators and kits
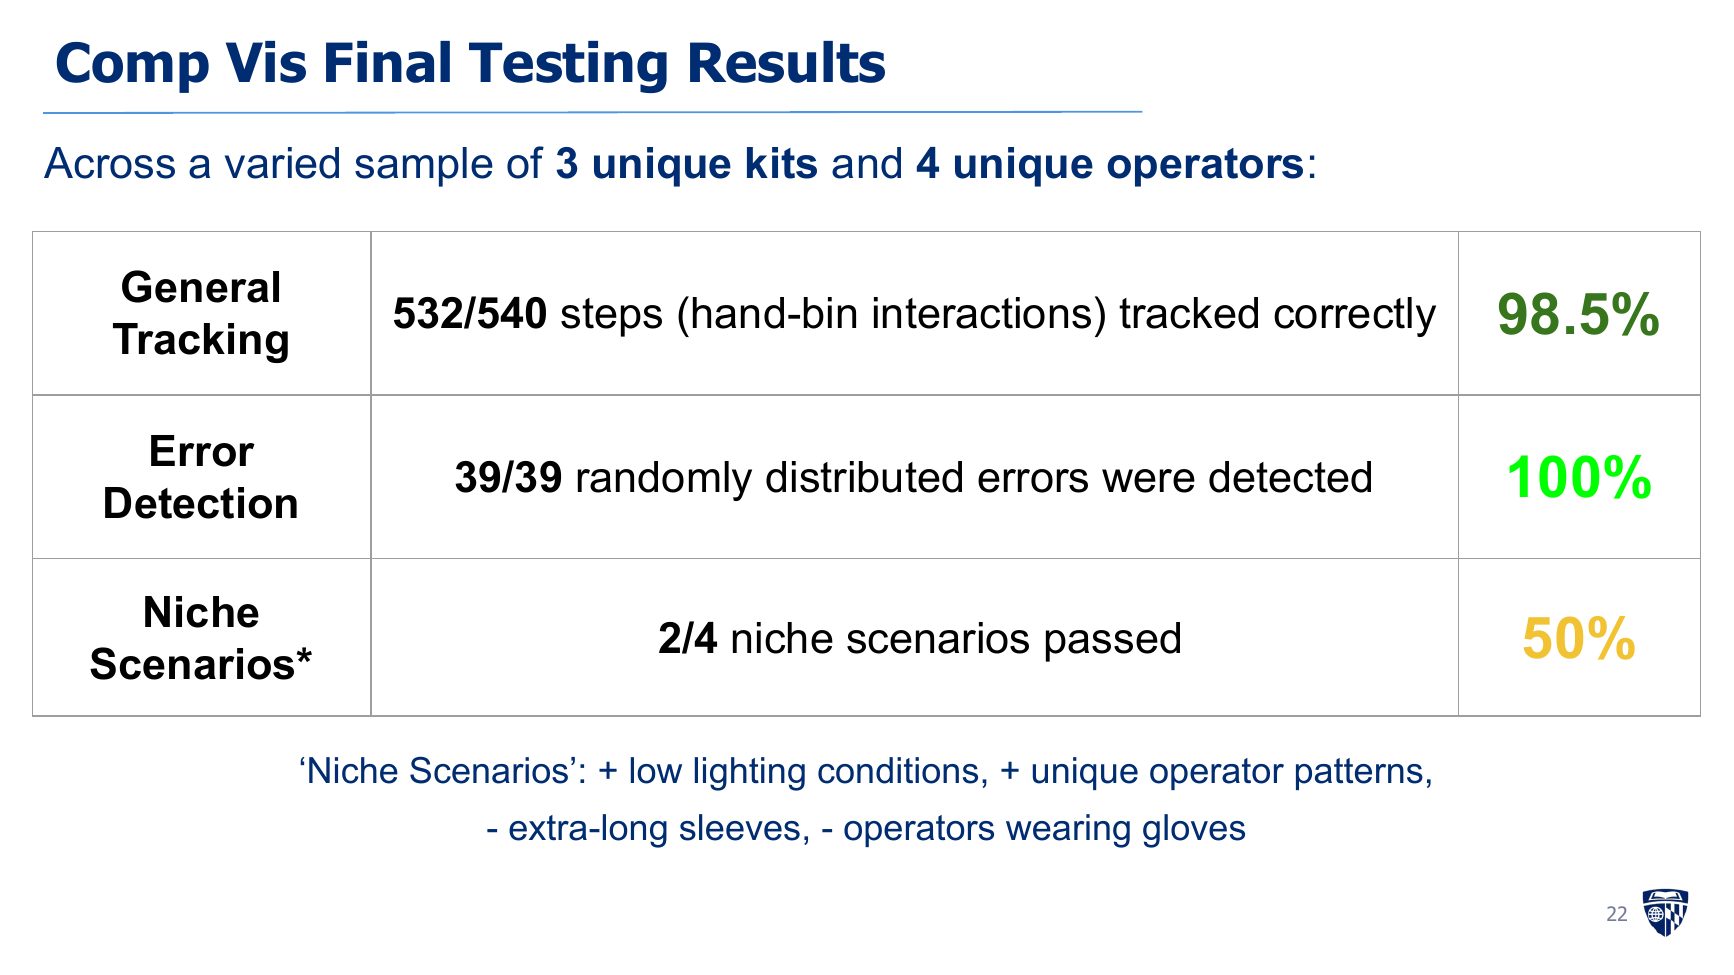
Validation covered kit recognition, sub-quarter-second hand detection, correct and intentionally incomplete sequences, reduced lighting, and multiple operators. The final trials tracked 532 of 540 hand-bin interactions and caught every one of the 39 deliberately introduced missing-part errors. Testing also exposed the next development priorities: only two of four niche scenarios passed, with extra-long sleeves and gloves requiring further refinement.